05.1 VINEYARD-AI
Vineyard AI Field
From drone imagery to a map of every block, row and vine, with a walking route for inspectors: 14 km instead of 68 km on the hackathon reference data.
Datasheet
- Org
- Solemtrix
- Status
- Hackathon build, DeepTech GigaHack 2026. Code public under the MIT licence.
- Period
- 2026-09
- Layer
- Intelligence
- Role
- I worked on the computer vision and the machine learning: the AI pipeline, the U-Net and the route solver.
Problem
In the Republic of Moldova, town halls, the National Office of Vine and Wine (ONVV) and the Agency for Interventions and Payments in Agriculture (AIPA) need a vine-by-vine inventory: blocks, rows, vines, planting gaps and waste.
The GigaHack challenge was to build that inventory from drone imagery, measure it, and plan an inspection route that people can walk.
What was built
We went OpenCV first. With only two labelled tiles, classical computer vision beat a U-Net: vegetation masks in the Lab colour space, row detection by autocorrelation, and splitting each row into single vines. We kept the neural network only where computer vision could not see well. Everything runs on CPU, on an ordinary laptop.
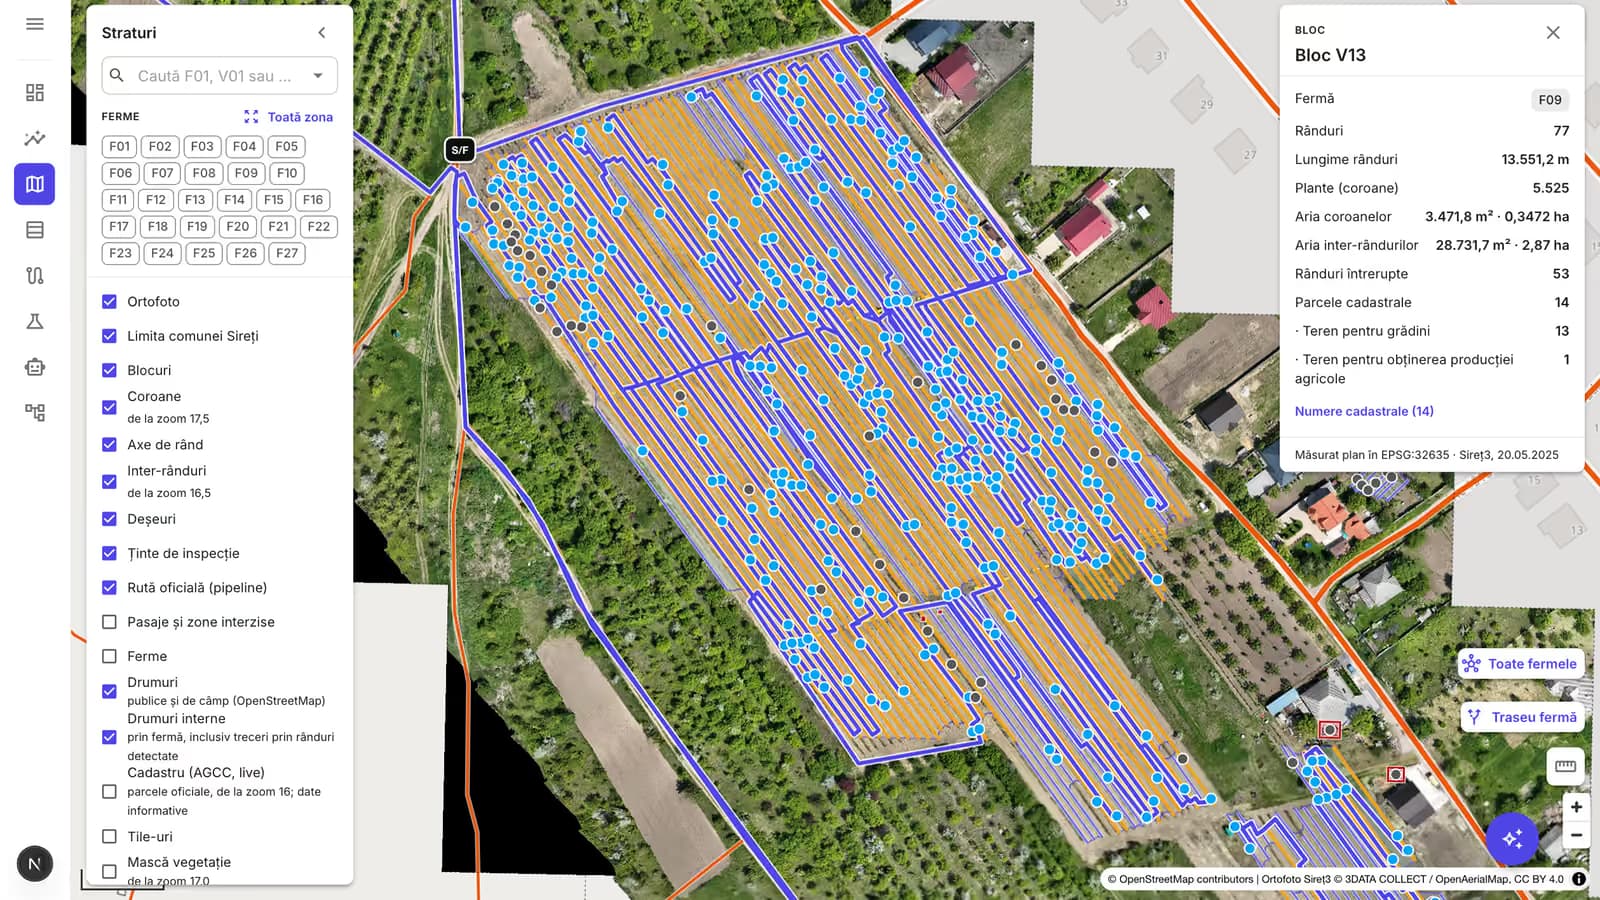
The platform maps every block, row, vine, planting gap and waste item with a stable ID, and measures canopy area, inter-row area and row lengths. OR-Tools plans the inspection route.
Răzvan Pervulescu built the web app, which assigns field tasks to inspectors, with roles and notifications. Maximilian Racz and Mădălin Ghilezan built the hardware, including a robot that drives through the vineyard: an ESP32 with a pan/tilt camera, driven from the web app, that gives every row its own “Street View”.
Technologies
- Python
- OpenCV
- PyTorch
- U-Net
- SAM 3
- GeoPandas
- rasterio
- OR-Tools
- Next.js
- Supabase
- ESP32
Result
On the hackathon reference data, the platform found 44 blocks and 674 rows: 47.7 km of rows on about 81 ha.
The inspection route is 14 km instead of 68 km, 79% less walking.
On the reference tiles, row detection reached an F1 score of 1.00 and the inter-row IoU was 0.96.
Highlights
- Team Solemtrix, DeepTech GigaHack 2026
- OpenCV first, U-Net only where needed, CPU only
- Open source, MIT licence
- Hardware and field robot: Maximilian Racz and Mădălin Ghilezan
- Web app: Răzvan Pervulescu
Sources
Where the facts and numbers on this page come from.